

Updated October 2026: We removed per-tool accuracy percentages for Pix4D, Metashape, DJI Terra and OpenPointClass that had no published source, and replaced them with the published benchmark scores (RandLA-Net 77.4% and KPConv 74.6% mIoU on Semantic3D; 70.0% and 70.6% on S3DIS; PointNet 47.7% on S3DIS) and Pix4D’s own 2017 test (16–41% of points mislabeled on unseen aerial datasets). We also explained that mIoU is not an error rate, corrected LAS classes 0 and 1, and updated the Metashape 2.x menu names, the OpenPointClass command-line usage and its supported classes (20 ASPRS codes plus class 64). We removed the claim that Metashape lets you train a custom classifier, moved “best for custom classes” to OpenPointClass, changed Pix4D’s method from “Random Forest” to machine learning, and dropped an unsourced “AI saves 60–80%” figure. UAV4GEO is now described as the company behind WebODM, which has been separate from OpenDroneMap since April 2026, and the no-published-accuracy statements are scoped to the tools compared here. The dense-cloud step now says the photogrammetry output carries RGB color as well as XYZ, not geometry only.
You’ve got a 50-million-point cloud from a 500-image drone survey. Manual classification takes days. AI tools promise automation. Some deliver. Most don’t. Here’s what actually works.
In the past 18 months, Pix4D added machine learning classifiers to Pix4D Matic. Metashape 2.x integrated AI ground classification. DJI Terra reduced the workflow to a single button. But there’s a critical gap between what these tools claim and what they actually deliver — particularly accuracy. You will manually clean the results. AI saves time on the first pass, not the last mile.
This is what practitioners need to know about AI point cloud processing in 2026.
What “AI Classification” Actually Means
Before comparing tools, you need to separate the categories. “AI” covers four fundamentally different approaches:
Traditional physics-based filters — CloudCompare’s cloth simulation filter, statistical outlier removal, radius outlier removal. Not machine learning. These are mathematical operations on geometric properties: how your point relates to neighbors in 3D space. Fast, deterministic, no training required. Effective for noise removal, not class separation.
Machine learning classifiers — random forests and gradient boosted trees, as in OpenPointClass and in the method Pix4D published (Becker et al. 2017). Trained on labeled samples. The classifier learns decision boundaries from data you’ve already classified manually, then applies those boundaries to new data. Requires training data and you must know which features matter (geometry, color, elevation change). Success depends entirely on training sample quality.
Deep learning networks — PointNet, RandLA-Net, KPConv. Neural networks learn hierarchical features directly from point positions with no hand-engineered features. Published benchmark scores: on the Semantic3D outdoor benchmark (reduced-8), RandLA-Net reports 77.4% mean Intersection over Union (mIoU) and KPConv 74.6%. On the indoor S3DIS dataset (6-fold), RandLA-Net reports 70.0% and KPConv 70.6%, and the original PointNet 47.7% (Qi et al. 2017). mIoU is not an error rate. For each class it divides the points labeled correctly by all points that belong to that class or were predicted as it, then averages across classes, so a few small, hard classes pull it down. The share of points labeled correctly (overall accuracy) is much higher: 94.8% for RandLA-Net on Semantic3D. Research-grade. Not operator-ready.
Integrated AI classifiers in commercial software — Pix4D, Metashape, DJI Terra. Pre-trained models, one-click operation. No manual training. Works out of the box for standard classes: ground, vegetation, buildings, roads. Moderate accuracy. Real speed savings on the first pass.
This distinction matters, but don’t read any benchmark number as a forecast for your site. Pix4D’s own researchers (Becker et al. 2017) trained a classifier on two of their aerial-image photogrammetry datasets and tested it on a third it had not seen. Even using color, it mislabeled 16–41% of points, depending on the dataset, generally more than when training and testing on separate halves of the same dataset. How closely your site resembles the training data matters more than an algorithm’s headline score.
The Tools That Actually Work
Here’s the current state of AI point cloud processing, ranked by practical adoption and real-world results.
| Tool | AI Method | Standard Classes | Ease of Use | Cost | Best For |
|---|---|---|---|---|---|
| Pix4D (Mapper/Matic) | Machine learning on geometry + color | Ground, Vegetation, Building, Road, Human-Made Object | One-click in Matic | Subscription only: Pix4Dmapper $3,990/yr, PIX4Dmatic from $2,290/yr | Integrated photogrammetry-to-classification workflow |
| Metashape 2.x | Machine learning classifier | Ground, High Vegetation, Building, Road, Car, Man-made | One dialog (Tools > Point Cloud > Classify Points) | $3,499 perpetual | Python API for scripted pipelines; 3D model quality |
| DJI Terra | Ground classification + smart ML | Ground vs. non-ground + 3+ classes | Single button | $1,540/yr (Pro) | DJI Mavic/Air/Matrice users; simplicity |
| LP360 Drone (Drone Edition) | Deep learning (pre-trained) | Ground + utilities (power lines, poles, towers) | Moderate; utility-specific | $5,585 perpetual or $1,675/yr + AI add-on $5,280/yr | Transmission corridor mapping, utility asset detection |
| OpenPointClass | Random Forest / gradient boosted trees | Custom (20 ASPRS LAS 1.4 classes plus class 64 supported) | Command-line (pctrain, pcclassify) | Free, open-source | Budget operators, custom class training |
| CloudCompare + 3DMASC Plugin | Random Forest (user-trained) | Custom, user-specified | Moderate; requires training | CloudCompare free; plugin free | Custom classification, visibility in 3D |
| Trimble RealWorks / TBC | Deep learning (customizable) | Custom, user-trainable | Complex; enterprise UI | Custom pricing (contact Trimble) | Enterprise Trimble workflows, large-scale asset management |
| ArcGIS Pro | RandLA-Net (Python API) | Custom (your choice) | Steep; requires PyTorch setup | $700 annual ArcGIS Creator license | GIS-first workflows, batch processing, research-grade accuracy |
The Integrated Tools: Pix4D, Metashape, DJI Terra
Pix4D Matic (2024+):
Easiest entry point for integrated AI point cloud processing. Import your cloud or process imagery directly in Matic. Run “AI Classification” from the menu. The pre-trained machine-learning model evaluates each point on geometry (curvature, elevation, normal direction) and color. Ground, vegetation, buildings, roads — delivered out of the box. No training. Results in 5–15 minutes depending on cloud size.
Pix4D does not publish an accuracy figure for the shipped classifier. Expect manual cleanup on building rooflines over trees and on dense understory vegetation misclassified as ground; tall grass is easily confused with small trees.
Export as GeoTIFF orthomosaic or LAS with classification codes. No LAZ (compressed). A 50-million-point cloud exports significantly slower than competing platforms — a known friction point.
Metashape Professional 2.x:
Classification integrates directly into the photogrammetry pipeline. Build the point cloud, then Tools > Point Cloud > Classify Points assigns any combination of six classes: Ground, High Vegetation, Building, Road, Car and Man-made. A Confidence setting (0–1) leaves a point unclassified when its class can’t be assigned reliably. For bare earth alone, Tools > Point Cloud > Classify Ground Points runs Metashape’s separate geometric ground filter.
The real advantage: Python API. Script the entire workflow — import, align, build dense cloud, classify, export LAZ. For teams processing 5+ projects monthly, automation savings compound. The Metashape 2.2 manual does not describe training your own classifier: you can assign classes by hand (Tools > Point Cloud > Assign Class), and Agisoft asks users to send manually labeled clouds to its support team to improve its model. For a custom class like “power poles,” train it in OpenPointClass or CloudCompare’s 3DMASC.
Agisoft publishes no accuracy figure for the classifier either.
DJI Terra:
Simplest interface for AI point cloud processing. DJI users (Mavic 3 Enterprise, Matrice 300) get ground classification automatically during orthomosaic generation. No separate step. No training. One checkbox.
DJI doesn’t publish an accuracy figure, but the friction is zero. If you’re already in Terra and don’t need fine-grained classification, it’s sufficient for a first pass.
Cost: $1,540/year (Pro tier). Locked to DJI hardware.
OpenPointClass: The Free Alternative
Built by UAV4GEO, the company behind WebODM (a separate project from OpenDroneMap since April 2026). Free, open-source, command-line tools (pctrain and pcclassify).
It uses random forests (the default) or gradient boosted trees — not neural networks. Its README lists 21 supported classes: 20 ASPRS LAS 1.4 codes, including ground, low/medium/high vegetation, building, water, rail, road surface, the wire and transmission-tower classes, bridge deck, plus a human-made object class it numbers 64 (in the spec’s user-definable range). The project says it classifies 15 million points in under 2 minutes on a 4-core Intel i5 — CPU-native, no GPU required.
Accuracy: no published figure. pctrain ground_truth.ply --eval test.ply scores a model against a labeled cloud you held back from training, so you can measure accuracy on your own data instead of trusting a number.
Workflow:
- Train a model on labeled data:
pctrain --input labeled.las --output model.bin - Classify new data:
pcclassify --input raw.las --model model.bin --output classified.las - Review in CloudCompare, export as classified LAZ
The advantage: Built-in training via pctrain — label a subset of your data, train a model, apply to new projects. No TensorFlow, no PyTorch, no ML expertise beyond labeling points. CPU-native means it runs on any hardware — no NVIDIA GPU requirement.
For operators on tight budgets who can work from the command line, OpenPointClass delivers a trainable classifier without subscription or vendor lock-in.
What The Commercial Tools Get Right (And Wrong)
Pix4D’s integrated workflow: Process images, get a dense cloud, and classify in one ecosystem. No export/import friction. Results feed directly to orthomosaic generation and deliverables.
Metashape’s Python API: Script the entire pipeline including classification. Batch-process 10 datasets in one command. No commercial competitor does this cleanly.
DJI Terra’s simplicity: If your pipeline is DJI hardware + Terra, classification adds zero friction. Single checkbox during orthomosaic generation.
LP360’s utility focus: The only tool explicitly designed for power line and transmission tower detection. Purpose-built for corridor surveys. Other tools classify poles as “vertical objects.” LP360 distinguishes utility poles from streetlights and fences.
What they all get wrong:
No vendor publishes head-to-head accuracy comparisons. Marketing materials and case studies replace independent benchmarks. Research scores such as RandLA-Net’s 77.4% mIoU on Semantic3D are measured on curated datasets and can’t be compared with a vendor’s “accuracy.” Manual cleanup is unavoidable.
All struggle with mixed classes. A dense shrub taller than grass but shorter than a tree gets misclassified. Rooflines touching tree canopy confuse the classifier. Sloped terrain with vegetation creates ambiguity. Manual cleanup isn’t optional — it’s standard practice.
The Practical Workflow: From Raw Cloud to Deliverable
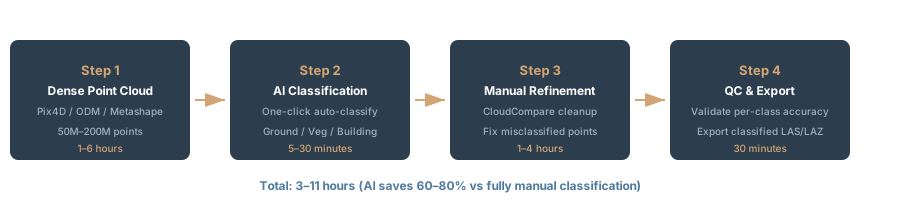
This is the actual process practitioners follow:
Step 1: Generate dense point cloud Process images through Pix4D, Metashape, or WebODM. Output: LAZ point cloud with XYZ coordinates and RGB color, no classification yet.
Step 2: Automated classification Run the AI classifier in the same software or export to OpenPointClass:
- Pix4D: Click “AI Classification” in Matic
- Metashape: Tools > Point Cloud > Classify Points
- DJI Terra: Check classification box during orthomosaic generation
- OpenPointClass (command line):
pcclassify input.laz classified.laz model.bin(LAS/LAZ input needs a build with PDAL; without it, PLY only)
Time: 5–20 minutes depending on cloud size and hardware.
Step 3: Manual refinement Export classified cloud to CloudCompare with the classification color map. Manually reclassify errors:
- Rooflines misclassified as vegetation
- Understory shrubs misclassified as ground
- Tall grass misclassified as trees
- Building edges bleeding into adjacent classes
This takes 30% of total classification time. Every commercial operator performs this step.
Step 4: QC and export Final pass in CloudCompare for obvious gaps or errors. Export as classified LAZ with proper class codes (0 = created, never classified; 1 = unclassified; 2 = ground; 3 = low vegetation; 4 = medium vegetation; 5 = high vegetation; 6 = building, per the LAS 1.4 R15 spec).
Use the classified LAZ for:
- Digital terrain models (ground only)
- Vegetation volume calculations (vegetation classes)
- Building footprint extraction (building class)
- Infrastructure asset identification (utility poles, wires, roads)
Accuracy: What Actually Works
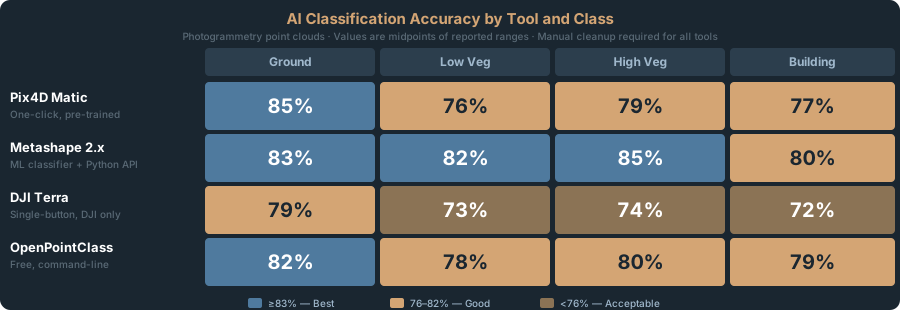
Research benchmarks report deep learning results as mIoU: 77.4% (RandLA-Net) and 74.6% (KPConv) on Semantic3D; 70.0% (RandLA-Net) and 70.6% (KPConv) on S3DIS; 68.6% for KPConv on ScanNet. Those are averages of per-class overlap scores, not the share of points misclassified; RandLA-Net’s overall accuracy on Semantic3D is 94.8%. Neither number transfers to your data. In the Becker et al. (2017) test, a color-aware classifier mislabeled 16–41% of points on aerial datasets it had not been trained on.
On a 50-million-point cloud, even a few percent is more than a million wrong points. You won’t catch all of them manually, so label a sample of your own data and measure accuracy on it rather than trusting a headline figure.
What affects accuracy most:
Point cloud density. Sparse LiDAR (2–5 points/m²) is harder to classify than dense photogrammetry (50+ points/m²). More points provide more local geometry context, improving classification.
Color information. In Becker et al. (2017), adding color cut the error on unseen datasets from 33–48% (geometry only) to 16–41% (Ankeny 46% to 24%, Building 33% to 16%, Cadastre 48% to 41%). RGB channels help classifiers separate grass (green) from concrete (gray) from building materials.
Vegetation complexity. Isolated trees are easier than dense understory or mixed shrub and grass. Classifiers see geometry, not plant species.
Slope and terrain. Flat ground is easier than steep slopes, where classifiers can mistake slope angle for class boundaries.
Training data quality. Custom classifiers trained on mislabeled data perform worse than pre-trained models. Rigorous labeling is essential.
Hardware Requirements: RAM Beats GPU
GPU is necessary but not sufficient. RAM is the real bottleneck for AI point cloud processing.
Classification speed scales with RAM first, GPU second:
| Cloud Size | Recommended RAM | Recommended GPU | Processing Time |
|---|---|---|---|
| <20M points | 32 GB | RTX 3060 (12GB VRAM) | 3–5 min |
| 20–100M points | 64 GB | RTX 4070 (12GB VRAM) or RTX 6000 (24GB) | 8–15 min |
| 100–500M points | 128 GB | RTX 6000 (24GB) or A100 (40GB) | 20–45 min |
| >500M points | 256 GB | A100 (40GB) + multi-GPU | 60+ min |
GPU specifics:
NVIDIA CUDA is required for Pix4D and Metashape GPU acceleration as of April 2026. OpenPointClass is CPU-native and runs on any hardware — no GPU dependency.
RTX series (consumer): sufficient for datasets under 100M points. RTX 4090 is overkill unless you classify constantly.
RTX A-series (workstation): RTX 6000 Ada (48GB VRAM) worth the investment if you process 200M+ points regularly.
A100 / H100 (enterprise): Overkill for classification alone. Justified only if you’re training custom classifiers.
Storage: NVMe SSD is non-negotiable. Classification reads the entire cloud into GPU memory then into RAM. HDD bottlenecks I/O and masks actual hardware performance.
When to Skip Commercial Tools and Use Research Code
Deep learning models — PointNet, RandLA-Net, KPConv — are published with pre-trained weights available in open-source frameworks (PyTorch, TensorFlow). They top the published research benchmarks.
But they require:
- PyTorch or TensorFlow installation
- GPU CUDA toolkit knowledge
- Custom inference scripts
- Model output debugging
- Edge case handling in production
ArcGIS Pro supports RandLA-Net via the deep learning Python API. If you’re an ArcGIS user with Python experience, that’s the closest path to research-grade accuracy in a commercial product. Otherwise: stick with one-click tools.
FAQ
Q: Can I classify drone photogrammetry point clouds the same as LiDAR data?
A: Yes, but expect some accuracy loss. Photogrammetry clouds are noisier than LiDAR but denser, and classifiers trained on LiDAR tend to perform worse on photogrammetry. Train or test on data like yours: OpenPointClass lets you train on your own labeled photogrammetry clouds.
Q: Which tool separates vegetation from ground best?
A: No vendor publishes a comparison, so we can’t rank them on numbers. Pix4D and Metashape both separate ground from vegetation out of the box; LP360 targets power line detection, not vegetation. For vegetation-specific work (low shrub vs. medium tree), train a model on your own labeled data in OpenPointClass or CloudCompare’s 3DMASC and measure it on a held-back sample.
Q: Is CloudCompare’s CSF filter AI?
A: No. Cloth Simulation Filter is deterministic physics simulation, not machine learning. A virtual cloth drapes over terrain, then pulls upward, revealing ground below and non-ground above. Effective for terrain plus vegetation, useless for vegetation plus buildings. Fast, free, no training. Use it for first-pass ground/non-ground splitting before ML classification.
Q: Can I batch-process multiple datasets automatically?
A: Metashape Python API has native support. Pix4D command-line is not straightforward. OpenPointClass has a CLI but minimal documentation. LP360 offers batch mode in Drone Edition. CloudCompare/3DMASC supports batch via CloudComPy (Python wrapper). Best option: Metashape for automation, manual runs for single projects.
Q: Do I actually need a GPU?
A: Yes. CPU-only on 50M points: 30–60 minutes. GPU (RTX 3060): 8–12 minutes. That 4–5x speed difference compounds across multiple projects per week. GPU is non-negotiable if classification is part of regular workflow.
Q: What if my point cloud has strange colors (bad white balance, overexposed)?
A: Integrated classifiers (Pix4D, Metashape, DJI Terra) use color alongside geometry. Poor color reduces accuracy. Pre-trained models trained on normal imagery perform worse on color anomalies. Training your own model on your data (OpenPointClass, 3DMASC) can recover some of it. For consistently bad color, geometry-only classification (CloudCompare CSF + 3DMASC Random Forest) may outperform color-dependent models.
Bottom Line
AI classification speeds up the first pass, but every deliverable requires manual cleanup on rooflines, vegetation edges, and complex terrain. Practical workflow: auto-classify in Pix4D or Metashape (5–15 minutes), refine in CloudCompare (30–60 minutes), export.
Best free option: OpenPointClass — no subscription, trainable on your own data, CPU-native, command-line interface.
Best integrated option: Pix4D Matic or Metashape 2.x depending on existing workflow. One-click, no published accuracy figure, manual cleanup essential.
Best for utilities and corridors: LP360 Drone Edition — pre-trained on power line and tower detection. Expensive and purpose-built, worth it if that’s your core work.
Best for custom classes: OpenPointClass — label a sample, train with pctrain, and apply the same model to dozens of projects with pcclassify.
Don’t chase deep learning research code without PyTorch expertise. None of the classifiers compared here publishes an accuracy figure for your kind of site, so measure it on a labeled sample of your own data. Plan 30–60 minutes of manual cleanup per dataset even with the best tools.
The efficiency gain is real. Time saved comes on the front end, not the back end.
Related Reading
For detailed software selection across the entire photogrammetry pipeline: Pix4D vs Metashape vs WebODM vs RealityScan
For accuracy fundamentals: Drone Survey Accuracy: What Checkpoint RMSE Actually Means
For data source differences in classification: LiDAR vs Photogrammetry
For post-processing workflows with classified clouds: QGIS for Drone Data
For self-hosted processing: WebODM Local Installation
For flight planning that impacts classification inputs: GSD Calculator
References
Research and standards cited in this article.
- Becker, C., et al. (2017). Classification of aerial photogrammetric 3D point clouds. ISPRS Annals of the Photogrammetry, Remote Sensing and Spatial Information Sciences, IV-1/W1, 3–10. doi:10.5194/isprs-annals-IV-1-W1-3-2017
- Hu, Q., et al. (2020). RandLA-Net: Efficient semantic segmentation of large-scale point clouds. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 11105–11114. doi:10.1109/CVPR42600.2020.01112
- Qi, C. R., et al. (2017). PointNet: Deep learning on point sets for 3D classification and segmentation. Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition (CVPR), 77–85. doi:10.1109/CVPR.2017.16
- Thomas, H., et al. (2019). KPConv: Flexible and deformable convolution for point clouds. Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV), 6410–6419. doi:10.1109/ICCV.2019.00651